A gear choice made at the tooth stage can determine whether a compact drive runs quietly for years or loads its bearings beyond their limits. The question of spur versus helical gears is not a matter of one tooth form being universally better. It is a decision about load path, speed, noise, packaging, manufacturing route and the parts surrounding the mesh.
For a simple, low-speed mechanism, spur gears are often the clean answer. For a higher-speed enclosed drive where smoothness and torque density matter, helical gears can justify their added complexity. The useful comparison starts with what changes at the mesh.
Spur versus helical gears at the tooth contact
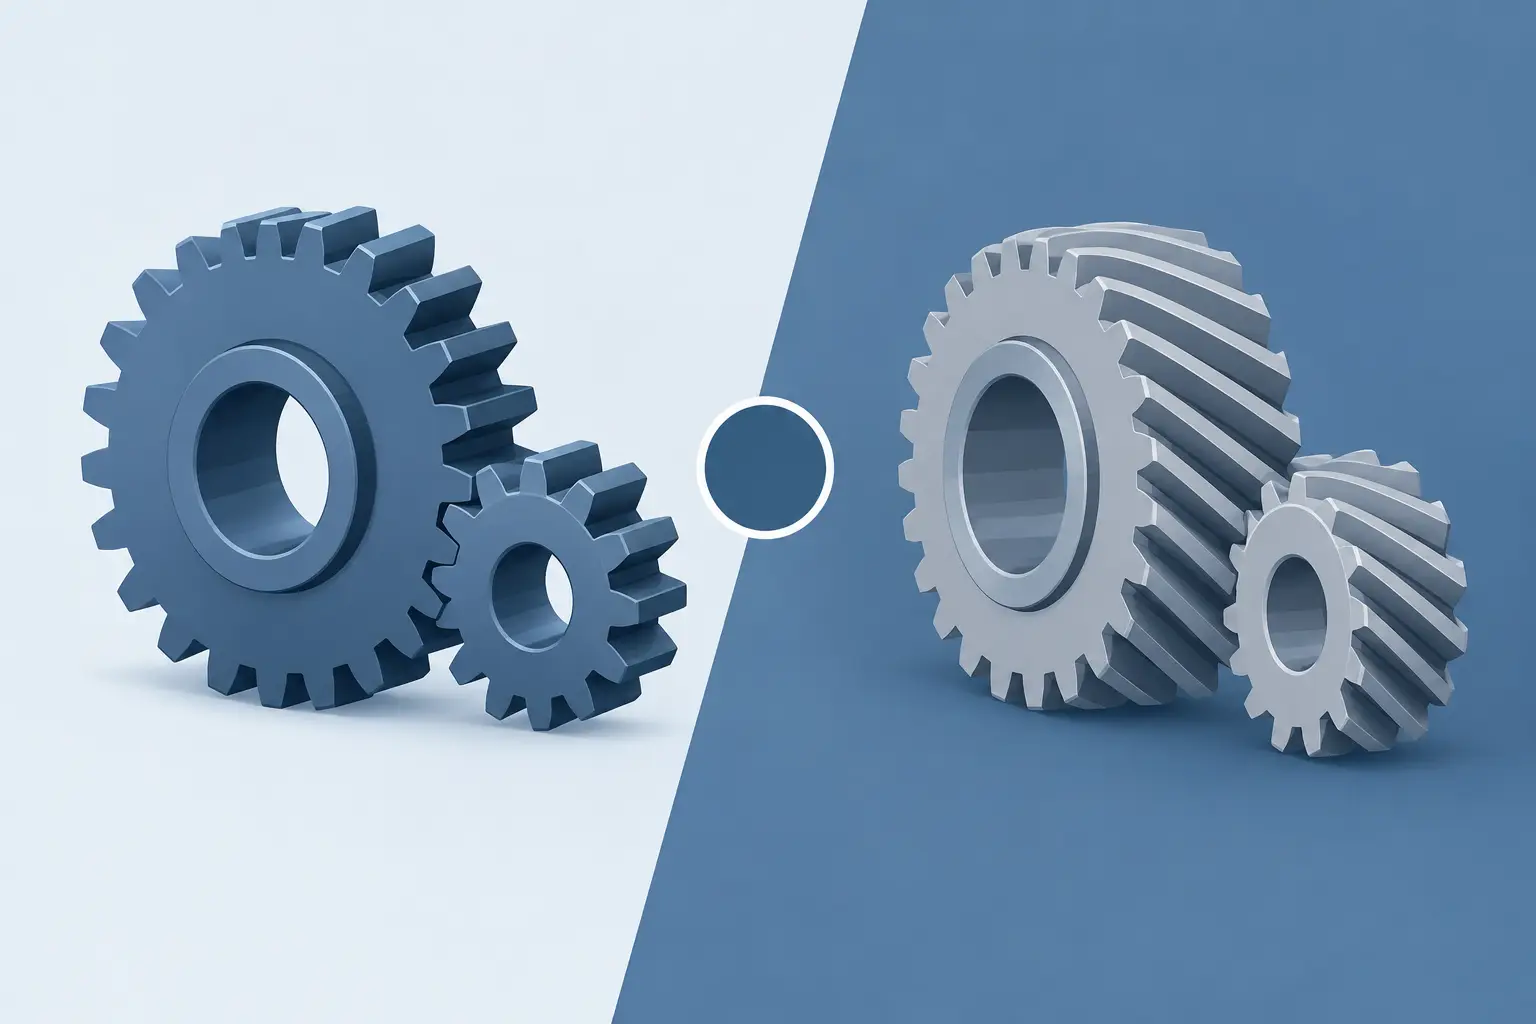
A spur gear has teeth parallel to its axis. As each pair of teeth engages, contact begins across the face width at roughly the same time. The geometry is direct, efficient and straightforward to inspect. With the correct module, pressure angle, centre distance and backlash, a spur pair transmits motion without axial thrust.
A helical gear has teeth set at a helix angle to the gear axis. Engagement progresses across the tooth face rather than arriving all at once. This produces a smoother transfer of load and usually a higher contact ratio. More than one tooth pair can share the transmitted load for a greater proportion of the mesh cycle.
That progressive engagement is the core advantage of helical gearing. It reduces the abruptness that causes vibration and gear whine in spur meshes. It also changes the force system. In addition to tangential force, which transmits torque, a helical gear generates radial force and axial force. The axial component is commonly approximated as tangential force multiplied by the tangent of the helix angle.
That force has to go somewhere. It passes into the shaft, bearings, housing and retaining features. A helical gear is therefore never just a gear decision.
Noise, speed and transmitted load
Spur gears are not inherently unsuitable for demanding work. Well-made spur gears with proper tooth form, backlash, alignment and lubrication can run reliably at significant loads. They are common in low-speed machinery, open gear trains, indexing systems and applications where cost and efficiency take priority over acoustic behaviour.
Their limitation becomes more visible as pitch-line velocity rises. The repeated entry of a full tooth face into mesh can excite the gear, shaft and housing. Manufacturing variation, runout and housing flexibility make this worse. A small gearbox can act as an effective loudspeaker when its natural frequencies line up with mesh frequency.
Helical gears generally run more quietly and with less vibration at the same duty. Their overlap along the face width smooths engagement, which is why they are widely used in vehicle transmissions, machine tools, enclosed reducers and compact industrial drives. The benefit is most valuable where the mechanism runs continuously, sits near an operator or must meet a controlled noise target.
Helical gears can also carry high loads in a compact envelope, but the claim needs context. Greater contact ratio can improve load sharing, yet rating depends on tooth strength, pitting resistance, face width, material, heat treatment, lubrication, alignment and allowable deflection. A wider spur gear may outperform a poorly supported helical gear. Tooth form does not replace engineering checks.
The axial-thrust trade-off
The main cost of a single-helical pair is thrust load. As helix angle increases, mesh overlap improves, but axial force rises. The bearings must be selected for that combined radial and axial duty, and the housing must locate them accurately enough to maintain the intended contact pattern.
This is where a promising gearbox layout often becomes impractical. A lightweight shaft supported only by deep-groove ball bearings may tolerate modest thrust, but it may not be the right arrangement for a high-torque helical stage. Angular-contact ball bearings, tapered roller bearings or a paired bearing arrangement may be required. Those choices consume axial space, affect assembly sequence and can increase housing cost.
Double-helical or herringbone gears can cancel axial thrust when correctly arranged, but they are not a free upgrade. They require more complex geometry and manufacture. They tend to suit specialist, high-load applications rather than a compact prototype or small production run.
Spur gears avoid this issue. Their force system still creates radial bearing load, but no axial component from the mesh itself. That simplifies shaft retention and bearing selection. For a rack-and-pinion drive, a spur pinion is similarly easier to support, while a helical rack and pinion may offer quieter motion at the cost of side thrust.
Efficiency and losses in real gearboxes
Spur gears usually have a small efficiency advantage because their tooth contact is primarily rolling with less sliding introduced by tooth orientation. In a well-built, lubricated gearbox, the difference between spur and helical stages may be modest. It can still matter in a battery-powered mechanism, a heat-limited enclosure or a multi-stage reducer where losses accumulate.
Helical gears introduce additional sliding and bearing losses associated with thrust. Lubricant selection and viscosity matter more as speed and contact stress increase. Too little lubricant risks scuffing and wear; excessive churning can create drag and heat. The correct answer depends on operating speed, oil bath depth, splash behaviour and whether the gearbox uses grease or oil lubrication.
Do not choose a spur stage solely because its theoretical efficiency is higher if the resulting noise forces heavier housing walls, lower speed or a different operating environment. Conversely, do not specify helical teeth simply because they sound premium. The complete system determines the useful efficiency.
Manufacture, inspection and assembly geometry
Spur gears are generally easier to produce and inspect. Their teeth can be cut, moulded, printed or machined using familiar processes, and the geometry is easier to communicate in drawings. For prototypes, non-critical fixtures and moderate-duty mechanisms, this simplicity is valuable.
Helical gears require controlled helix angle, handedness and normal tooth geometry. A mating pair must use opposite hands on parallel shafts. Designers also need to stay consistent about normal module versus transverse module, normal pressure angle and the derived transverse values. Mixing these definitions is a common source of incorrect centre distances and non-mating parts.
Manufacturing accuracy matters to both types, but helical meshes can be less forgiving of poor shaft alignment across a wide face width. Housing bores, bearing seats and shaft shoulders must hold the gears where the design expects them. A correct involute profile cannot compensate for a housing that allows shafts to tilt under load.
For additive manufacture, the decision needs extra care. Spur gears are easier to print and clean, particularly for visual prototypes and low-load mechanisms. Helical gears may print successfully, but tooth surface quality, layer direction, material anisotropy and post-processing can affect meshing behaviour. A printed gearbox should be treated as a test article unless its material, process and loading have been validated for service.
A practical selection method
Start with the duty rather than the gear type. Define torque, input speed, required ratio, operating hours, allowable noise, available centre distance and packaging limits. Then establish the shaft and bearing arrangement. If the assembly cannot accommodate axial thrust or needs the simplest possible support structure, spur gears are usually the sensible baseline.
Choose helical gears when smoother running, lower noise or high load capacity within a limited centre distance materially improves the machine. Specify a helix angle that provides useful overlap without imposing unnecessary thrust. Larger is not automatically better.
Next, inspect the complete mechanism. Check tooth interference, contact ratio, backlash, tip and root clearances, shaft spacing, bearing fits, housing wall thickness and tool access. Confirm that the gear face width is supported by shaft stiffness and bearing span. A face width that looks efficient on paper can produce edge loading when the shaft deflects.
Finally, design for the manufacturing route. A machined steel reducer, an injection-moulded actuator and a printed proof-of-concept do not deserve the same assumptions. GearSuite helps keep these decisions visible by connecting true involute geometry with shafts, bearings, housing interfaces and exportable assembly geometry before parts are made.
The right gear is the one that makes the complete transmission buildable, supportable and fit for its duty. Start with the forces the mechanism must carry, then let the tooth form earn its place.