A helical gear lead angle calculator is useful only when it preserves the geometry that actually reaches the shop floor. A plausible angle on screen is not enough. The selected lead, module convention, tooth count, pitch diameter, handedness and centre distance must still describe a true involute gear pair that can mesh, fit its shaft and sit inside a real housing.
For a single helical gear, the calculation is straightforward. For a mechanism, it is a design decision with consequences. Helix angle changes the transverse tooth geometry, creates axial thrust, affects bearing selection and can make an otherwise compact gearbox longer or harder to manufacture. Useful detail by default means seeing those consequences while the parameters are still easy to change.
What a helical gear lead angle calculator calculates
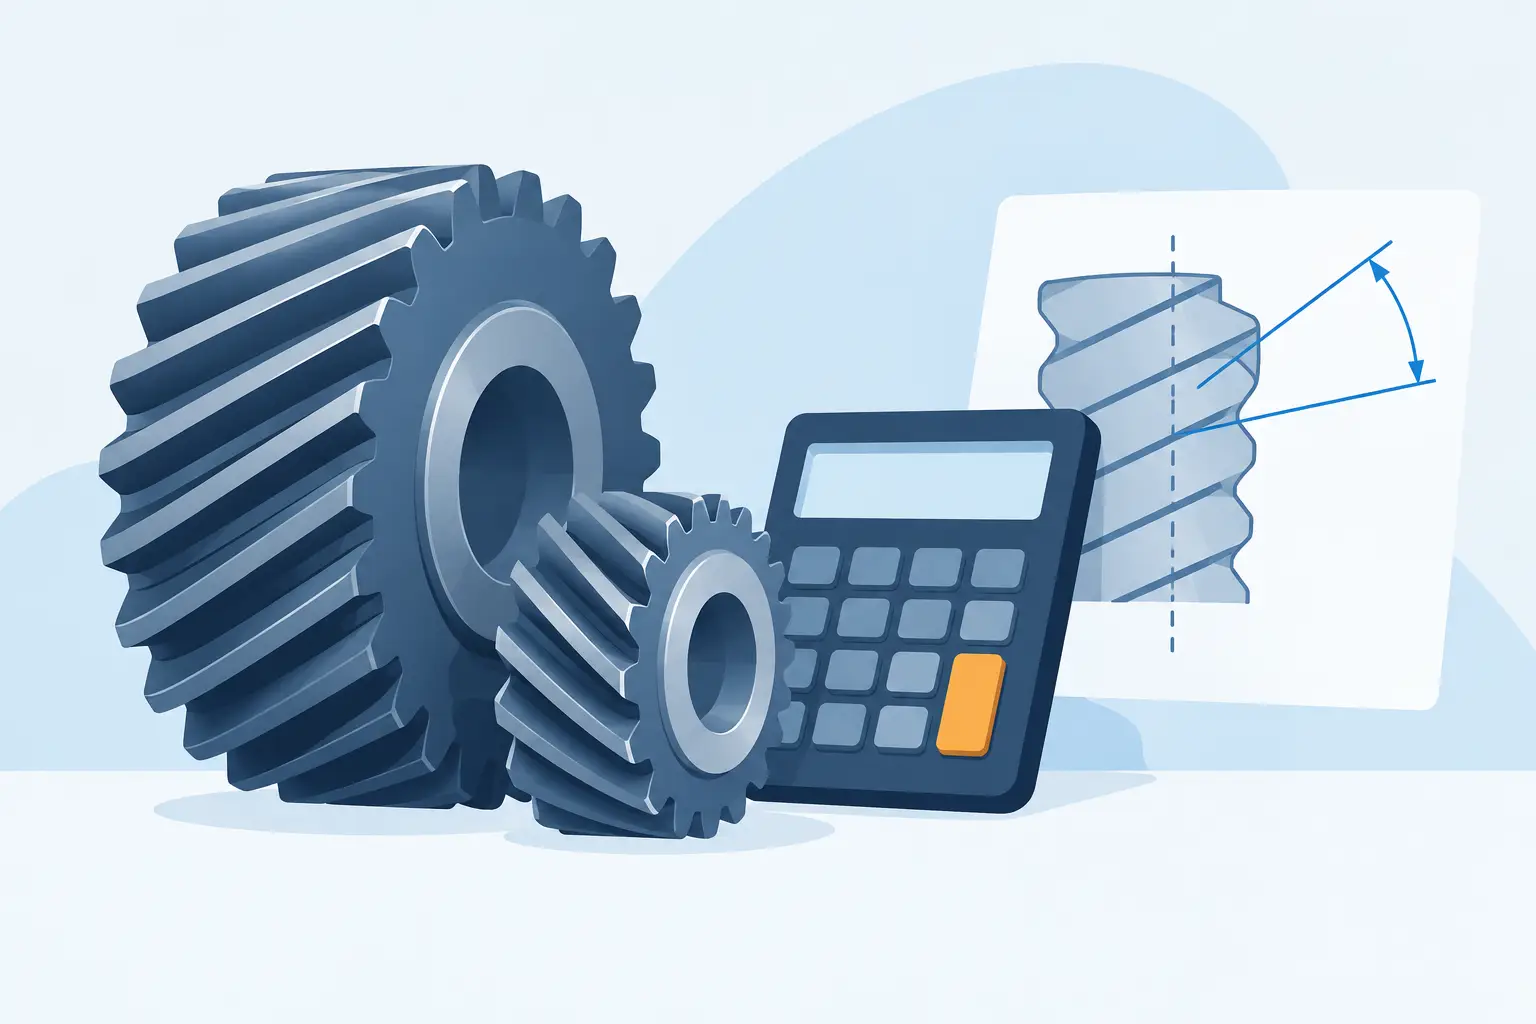
The terminology needs care. In helical gear work, helix angle is usually the angle of the tooth trace relative to the gear axis. Lead is the axial distance travelled by one tooth trace in one full revolution around the pitch cylinder. Some tools use “lead angle” to describe this same relationship; others reserve lead angle for worm gears. Before entering figures, confirm how the calculator defines the term.
At the pitch cylinder, lead and helix angle are related by:
`L = π × d × tan β`
where `L` is lead, `d` is pitch diameter, and `β` is helix angle.
Rearranged for a calculator that starts with lead:
`β = arctan(L / (π × d))`
This is not a cosmetic conversion. If the pitch diameter changes while lead remains fixed, the helix angle changes. If tooth count or module changes, the pitch diameter changes too. A copied lead value can therefore produce a different gear than intended.
For a helical gear pair, the mating gears must have the same helix angle magnitude and opposite hands. A right-hand pinion meshes with a left-hand gear. Two gears with the same hand generally do not form a standard parallel-axis external mesh.
Start with the tooth system, not the angle
A lead angle calculation should follow the tooth-system decision, not replace it. Select the pressure angle, normal or transverse module convention, tooth count and required ratio first. These values establish the gear geometry from which pitch diameter and lead can be evaluated.
For normal-module gears, the relationship is:
`m_t = m_n / cos β`
where `m_n` is normal module and `m_t` is transverse module. Pitch diameter is then typically calculated as:
`d = z × m_t`
where `z` is tooth count.
This is where many quick calculators become misleading. A user enters a module value, changes helix angle, and assumes the pitch diameter remains constant. That assumption is only valid if the tool clearly states it is using transverse module. With normal module held constant, increasing helix angle increases transverse module and pitch diameter.
The distinction matters for centre distance. For an external gear pair:
`a = (d₁ + d₂) / 2`
If the calculated diameters shift, the housing bore centres shift with them. In a compact drive, even a small change can conflict with bearing seats, wall thickness or a motor interface.
Choose inputs that match the information you have
A good calculator accepts the values available from the actual design brief. If you are replacing an existing gear, you may know its pitch diameter and measured lead. If you are creating a new reduction stage, normal module, tooth count, ratio and target centre distance are usually more useful starting points.
When lead is known, enter it with the pitch diameter at the pitch circle, not an outside diameter measured over tooth tips. Outside diameter is affected by addendum and profile convention. Using it in the lead formula produces an angle that looks close enough until the gears fail to match the intended centre distance.
When helix angle is known, calculate lead from the pitch diameter and retain sufficient precision. Rounding an angle to a whole degree may be acceptable for concept work, but it can create a measurable lead mismatch across a wide face. Keep the governing values consistent through the CAD model, manufacturing drawing and inspection plan.
Helix angle also needs a practical range. Lower angles reduce axial load and simplify bearing arrangements, but deliver less overlap between teeth. Higher angles can improve smoothness and load sharing, yet increase axial thrust and may require a wider face or more careful machining. There is no universally correct number. The right value depends on speed, load, noise targets, allowable package size, available bearings and production process.
Check mesh geometry after calculating lead
A calculated lead angle is only one result. Validate the pair as a pair.
First, confirm ratio and centre distance. The tooth counts define the nominal ratio, while the transverse geometry defines the pitch diameters and therefore the shaft spacing. Do not alter one gear independently to make a package fit unless you recalculate the full mesh.
Next, check transverse pressure angle. With a normal pressure angle `α_n`, the transverse pressure angle is:
`tan α_t = tan α_n / cos β`
This affects the involute geometry in the plane where the gears roll together. A calculator that reports lead but ignores pressure-angle conversion is not describing the complete tooth system.
Then inspect contact ratio and face width. Helical teeth gain axial contact ratio because the tooth trace progresses across the face during engagement. That is often the reason to specify helicals in the first place. But the gain depends on face width and helix angle together. A narrow gear with a steep helix may still deliver less useful overlap than expected.
Finally, calculate axial force. A common first estimate is:
`F_a = F_t × tan β`
where `F_t` is tangential tooth force. As helix angle rises, axial force rises quickly. This load must be carried through the shaft, bearings, housing shoulders and retention features. A gear calculator that shows the teeth but not the bearing implications leaves a critical decision hidden.
Avoid the common calculator failures
The most frequent failure is mixing normal and transverse values. Module, pressure angle and tooth thickness are linked conventions, not interchangeable labels. Record which plane each value belongs to.
The next is mismatched handedness. A beautiful 3D model can still be wrong if both external gears are right-hand or both are left-hand. Label hand explicitly in the design data and make it visible in the assembly view.
A third issue is treating lead as an isolated production dimension. A hobbing or milling operation must reproduce the specified tooth system, profile shift, lead direction and lead value. The supplier also needs tolerances appropriate to the gear quality and duty. “Helical, 20 degrees” is not a complete manufacturing definition.
There is also a packaging trap. Helical gears can reduce noise and improve engagement, but their thrust loads may demand angular-contact bearings, paired bearings or a more substantial housing arrangement than a spur stage. The apparent gain in compactness can disappear if the support structure is considered late.
Configure, inspect, validate, export
The most productive workflow is to configure the helical pair from its governing parameters, inspect the resulting assembly geometry, validate meshing and support conditions, then export production geometry. A separate lead-angle calculator remains useful for checking a supplier drawing or reverse-engineering a component, but it should not be the final authority for a complete drivetrain.
In GearSuite, a helical pair can be developed as true involute geometry within a mechanism-oriented workflow rather than as disconnected equations. That means checking the relationship between teeth, shafts, bearings and housing space while the design remains parametric. Decisions stay visible.
Use the calculated lead angle as a design checkpoint: does it match the intended module system, produce the required centre distance, preserve the correct hand and keep axial loads within the bearing arrangement? If the answer is uncertain, the number is not ready for manufacture yet.
The useful result is not an angle in a field. It is a gear pair whose tooth geometry, assembly geometry and production intent agree.