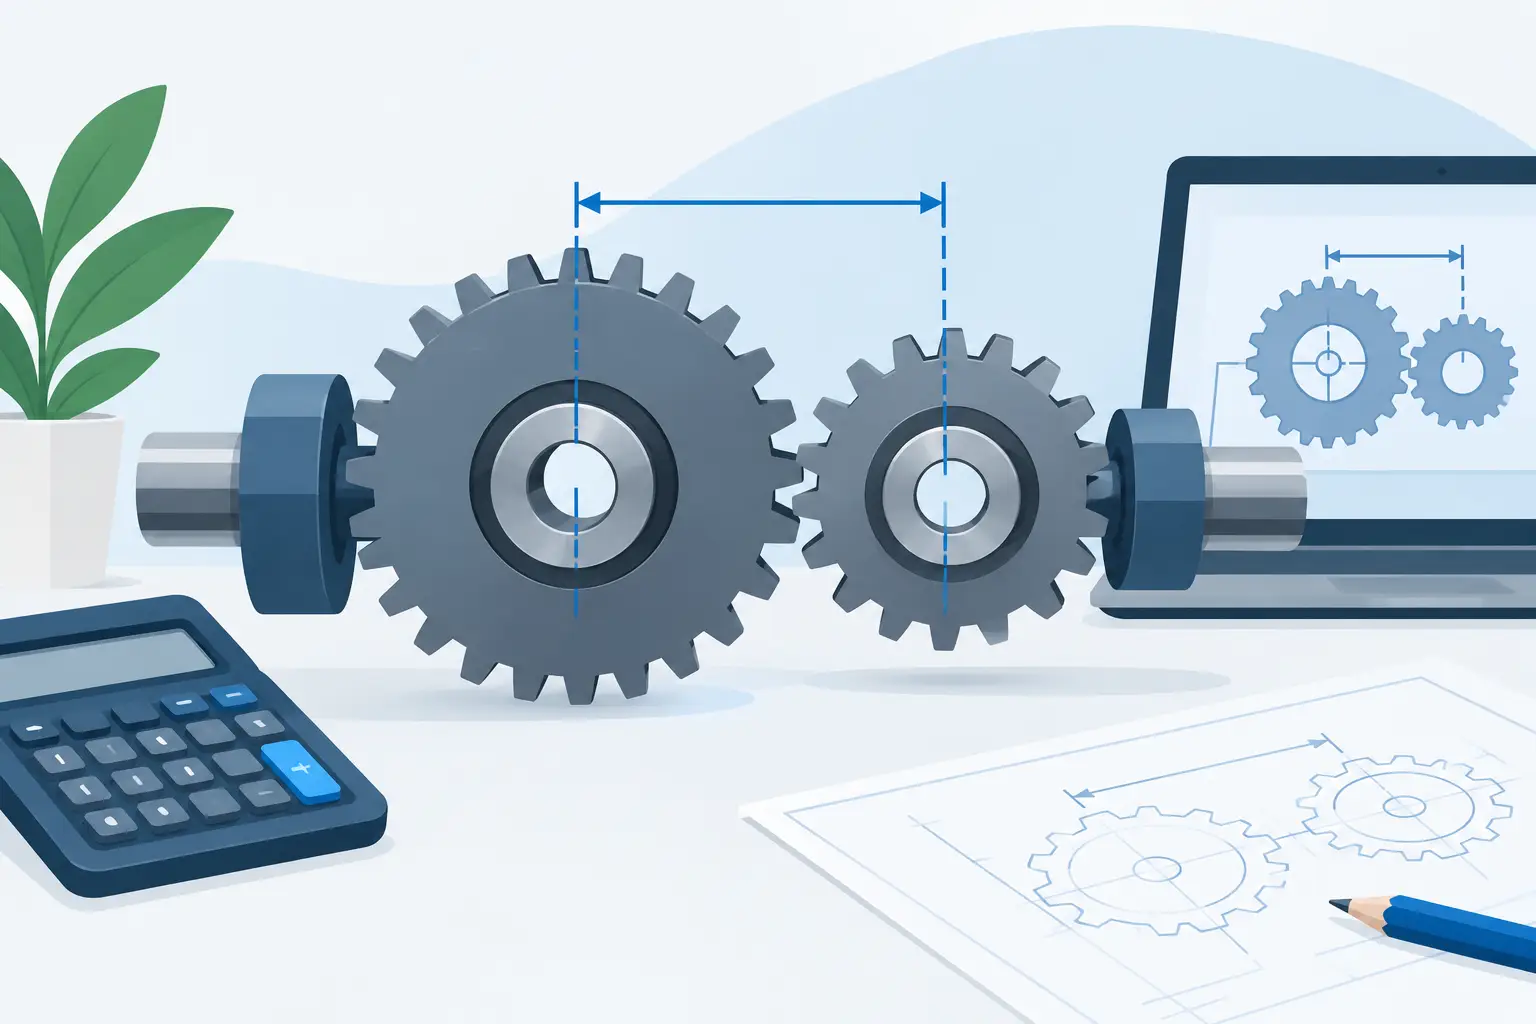
A gear pair can have the right ratio, module and tooth count yet still fail as an assembly because the shafts are not positioned correctly. A gear centre distance calculator gives you the starting dimension between shaft axes, but useful engineering begins with understanding what that dimension represents - and what it does not.
For a real mechanism, centre distance affects tooth contact, backlash, housing layout, bearing positions and whether the final parts can be manufactured and assembled without forcing the gears out of mesh. It is not a drawing convenience. It is assembly geometry.
What a gear centre distance calculator calculates
For two standard external spur gears with the same module and no profile shift, the nominal centre distance is:
`a = m × (z₁ + z₂) / 2`
Where `a` is the centre distance in millimetres, `m` is the module, and `z₁` and `z₂` are the tooth counts of the pinion and gear. A 20-tooth pinion meshing with a 60-tooth gear at module 2 has a nominal centre distance of 80 mm.
The same relationship can be expressed using pitch diameters:
`a = (d₁ + d₂) / 2`
This is often the clearest way to check a model. Each pitch diameter is module multiplied by tooth count, so the centre distance is simply half the sum of the two pitch diameters.
For imperial diametral pitch systems, use:
`a = (N₁ + N₂) / (2 × DP)`
where `DP` is diametral pitch and `N` is the tooth count. Do not mix module and diametral pitch values in the same calculation. They describe related geometry in different unit systems, and an apparently small mismatch produces completely incompatible teeth.
A calculator is useful because it removes arithmetic errors and exposes the relationship between tooth count, ratio and shaft spacing immediately. But it must use the same tooth system as the gears you intend to produce: matching module or DP, pressure angle, helix angle where relevant, and compatible tooth form.
Gear centre distance calculator inputs that matter
To calculate a nominal value, you need only module and tooth counts for a spur pair. To specify a buildable pair, you need more context.
The ratio comes from the tooth count relationship. A 20/60 pair gives 3:1 reduction, but the resulting centre distance depends on module. Increase module from 1.5 to 2 mm and the ratio stays exactly the same while shaft spacing, tooth thickness and torque capacity all increase. This is why choosing a ratio first does not finish the layout.
Pressure angle also matters. Standard 20-degree involute teeth are common because they provide practical strength and geometry across a wide range of applications. A different pressure angle can change base-circle geometry, tooth proportions and compatibility. Gears with equal module and tooth count are not automatically a valid mesh if their pressure-angle systems differ.
For helical gears, the module convention must be explicit. Most specifications use normal module, while centre-distance geometry is based on transverse pitch diameter. For parallel-axis helical gears with normal module `mₙ` and helix angle `β`:
`a = mₙ × (z₁ + z₂) / (2 × cos β)`
Equivalently, calculate transverse module first: `mₜ = mₙ / cos β`, then apply the spur-gear formula. Both gears must use the same normal module and helix angle magnitude, with opposite hands for a conventional parallel-shaft mesh. The centre distance rises as helix angle rises when normal module and tooth count remain fixed.
That trade-off is not academic. Helical gears can improve contact ratio and reduce perceived noise, but they introduce axial force. The shaft, bearing arrangement, housing and thrust reaction must be designed for it.
Nominal distance is not always the installed distance
The calculated value is normally the reference or nominal centre distance. It describes how standard gears mesh at their reference pitch circles. Production assemblies may intentionally use a slightly different installed distance to create working backlash or accommodate the design of the housing and bearings.
Moving standard involute spur gears farther apart increases working backlash and changes the operating pressure angle. Move them too far and contact becomes less favourable, tooth loading worsens and the contact ratio can fall. Moving them closer can reduce backlash, but may produce interference or tight running if there is no appropriate tooth modification.
This is why centre distance should never be used as a substitute for a backlash specification. Backlash is influenced by tooth thickness, manufacturing tolerance, gear quality, runout, housing tolerance, thermal expansion and the chosen operating centre distance. A small printed prototype may need visibly greater clearance than a precision-machined, lubricated gearbox. It depends on the process and intended duty.
For directional positioning, low backlash can be essential. For a general drive, some backlash is necessary to avoid binding as parts warm up or tolerances stack. The correct target is not zero. It is controlled clearance for the mechanism you are building.
Profile shift changes the picture
Profile shift is where a simple centre-distance calculation becomes a design decision. Positive and negative profile shifts alter tooth geometry, tooth thickness and addendum. Used properly, they can improve pinion strength, avoid undercut on low tooth counts, manage backlash or achieve a required centre distance.
For a pair with total profile shift coefficient `x₁ + x₂`, a common approximation is:
`a = m × [(z₁ + z₂) / 2 + x₁ + x₂]`
This is a useful reference for standard involute systems, not permission to select arbitrary corrections. The individual shifts must still produce adequate tip thickness, avoid interference and preserve acceptable contact conditions. A centre distance can be mathematically possible while the resulting tooth form is poor.
Low-tooth-count pinions particularly deserve attention. A standard 20-degree spur pinion with too few teeth can suffer undercut, reducing root strength. Profile shift may help, but it affects the mating gear and operating geometry. The right solution may instead be a different module, tooth count split, pressure angle or gearbox arrangement.
From shaft spacing to a complete assembly
The centre distance establishes the line between shaft axes. It does not establish where the shafts sit in a housing, how bearings are retained or whether the gear faces clear adjacent components.
Once you have the nominal value, inspect the complete assembly. Place the gears at their intended axial positions, then consider face width, hub geometry, keyways or clamping features, shaft shoulders, bearing widths and housing walls. A gear pair that meshes perfectly in a two-dimensional sketch may be impossible to assemble once a retaining nut or bearing seat is added.
For compact transmissions, centre distance also drives packaging. A larger gear often improves reduction ratio or torque capacity, but it increases housing envelope and may force longer shafts. A smaller module reduces spacing but can reduce tooth strength and make manufacturing tolerances more demanding. There is no universal best value.
Planetary systems add another constraint. The sun-to-planet and planet-to-ring relationships must satisfy their own geometry, while planet spacing and tooth-count conditions must allow equally spaced planets. Rack-and-pinion systems are different again: there is no second rotating shaft, so the relevant dimension is the pinion pitch radius from the rack pitch line, not a conventional gear-to-gear centre distance.
A practical calculation workflow
Start by fixing the transmission requirement: ratio, torque, speed, available envelope and manufacturing process. Select a compatible tooth system, then choose candidate tooth counts that achieve the ratio without creating an unnecessarily weak pinion.
Next, calculate nominal centre distance from the selected module and tooth counts. Treat this result as a controlled assembly dimension, not a number to round casually for a housing sketch. If the available shaft spacing is fixed, work backwards: determine whether another module, tooth-count pair or profile-shift strategy can meet it.
Then validate the mesh. Check pitch diameters, outside diameters, root clearances, contact ratio, interference risk and backlash target. For helical gears, include axial forces and bearing direction. For manufactured parts, account for the tolerance of the chosen process before committing to the housing.
Finally, inspect actual solids in assembly. True involute tooth profiles, shaft centres, bearings, hubs and casing features should be visible together. GearSuite supports this workflow by connecting parameter-driven gear geometry with assembly inspection, engineering checks and exportable production files. Decisions stay visible.
Common errors worth catching early
The most frequent error is calculating centre distance from outside diameters. Outside diameter is useful for clearance checks, but it is not the pitch diameter and does not define the correct shaft spacing. Use the pitch geometry.
Another is treating a ratio as proof of compatibility. A 2:1 ratio can be created by many tooth-count pairs, each with different centre distance, pinion strength and packaging consequences. Match the tooth system before considering the ratio solved.
It is also easy to overlook units. Module values are metric; diametral pitch is expressed in teeth per inch. Convert deliberately rather than entering a familiar-looking number into the wrong field.
Finally, do not assume a nominal CAD position creates a suitable running fit. Manufacturing variation, material behaviour and temperature all affect the final mesh. Design the clearance deliberately, particularly for additive manufacture and compact housings.
A gear centre distance calculator is most valuable when it feeds the next engineering decision. Calculate the shaft spacing, inspect the mesh, validate the constraints, then build the housing around geometry that can actually be made.