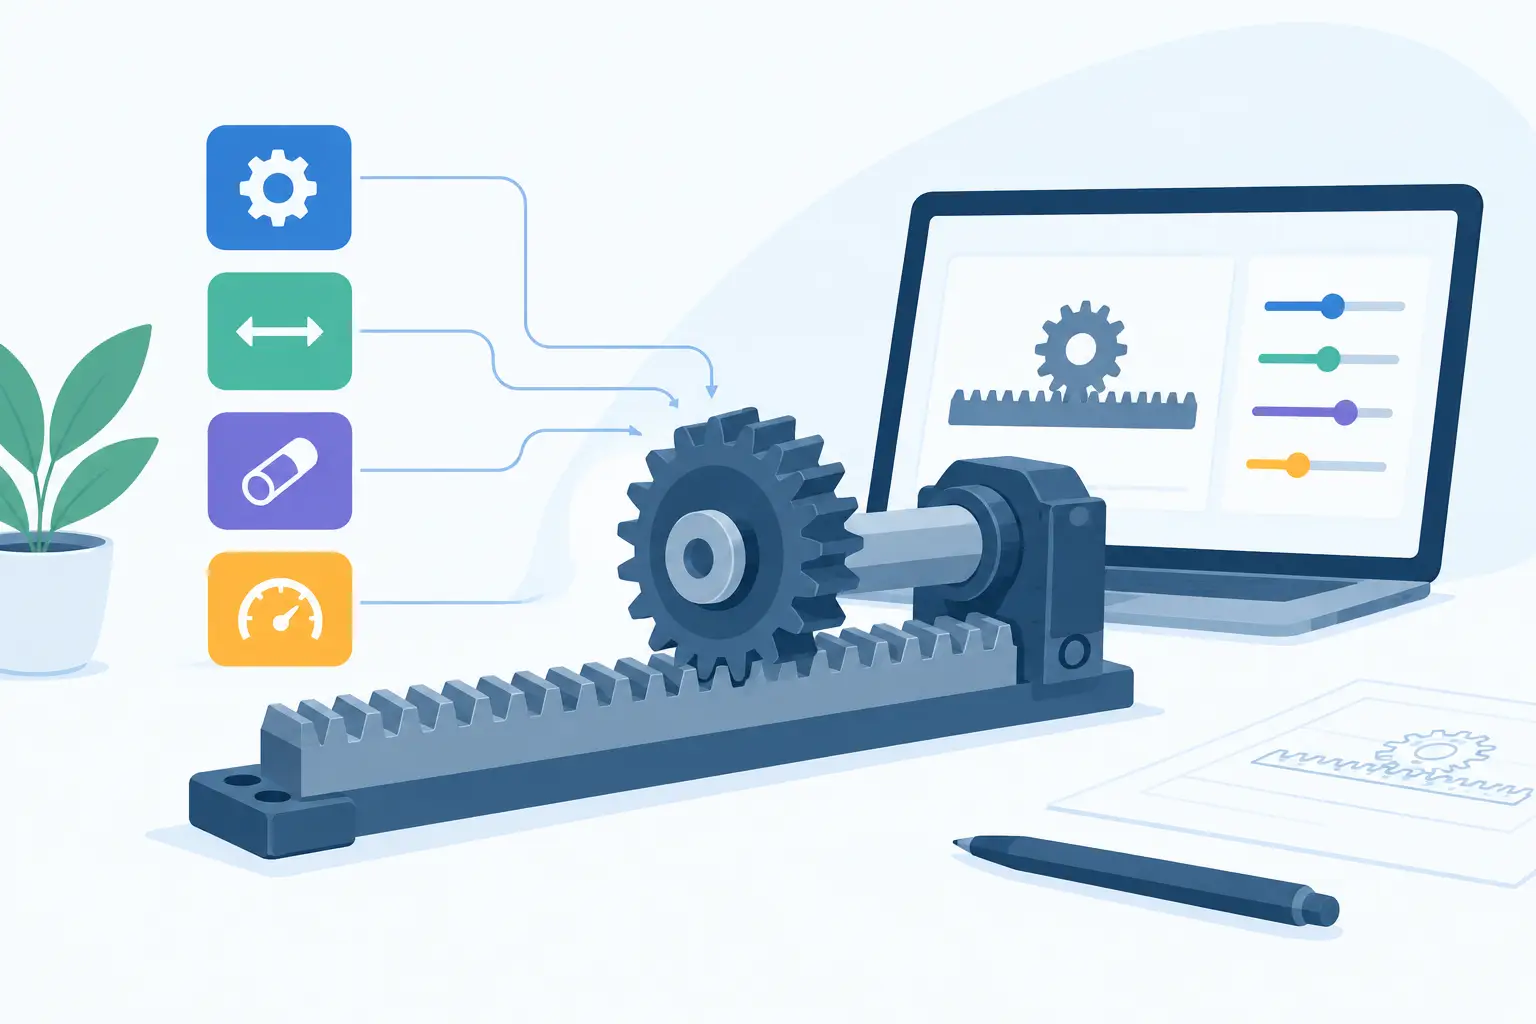
A rack that reaches the end of its stroke but cannot hold position under process load is not a successful design. Neither is a pinion that delivers the required travel speed while overloading its bearings or stripping teeth after a short duty cycle. A rack and pinion sizing calculator should expose these connected decisions early, before the mechanism becomes a set of difficult-to-change CAD parts.
Start with the linear duty, not the gear teeth
The rack converts rotary torque into linear force. That makes the required linear duty the correct starting point: payload mass, orientation, friction, acceleration, external process force, target speed and duty cycle. Tooth module and pinion diameter matter, but they are consequences of the load case rather than substitutes for it.
For a horizontal axis, the baseline linear force is commonly the sum of acceleration force, guide friction and any process force:
`F required = (mass × acceleration) + friction + process force`
A vertical axis also needs the gravitational component. If the mechanism must resist a load while stationary, include that holding force separately. Pneumatic clamps, cutting heads, spring loads and cable management can all create peak conditions that are absent from a simple travel calculation.
Apply a sensible service factor after identifying the real peak load. The right factor depends on shock, reversals, confidence in friction estimates and required service life. A lightly loaded inspection fixture has different needs from a production actuator that reverses thousands of times per shift. A calculator that accepts only nominal force can produce a neat answer that is not suitable for the machine.
Convert force into pinion torque
For a spur pinion, pitch diameter is determined by module and tooth count:
`Pitch diameter = module × number of teeth`
The pitch radius is half that diameter. Required pinion torque can then be estimated as:
`Torque = linear force × pitch radius ÷ efficiency`
Efficiency accounts for tooth contact, bearing losses, seals and the rest of the transmission. It should not be assumed to be perfect, particularly where preload, contamination control or multiple reduction stages are involved.
A compact example shows why the pitch diameter is significant. Assume an 80 kg horizontal carriage accelerates at 0.6 m/s². With 90 N of guide friction and 250 N of process load, the nominal requirement is 388 N. Applying a 1.5 service factor gives a design force of 582 N.
A module 2 pinion with 20 teeth has a 40 mm pitch diameter and a 20 mm pitch radius. At 90% efficiency, the required torque is approximately 12.9 Nm. That figure belongs at the pinion shaft. If a gearbox sits between motor and pinion, ratio, gearbox efficiency, reflected inertia and motor speed still need to be resolved.
Linear speed follows the same pitch geometry:
`Linear speed = π × pitch diameter × pinion speed ÷ 60`
At 120 rpm, that 40 mm pinion produces roughly 0.25 m/s of rack travel. Increasing pinion diameter raises travel per revolution and reduces torque for a given linear force, but it also raises the motor speed requirement for a given cycle profile and can make packaging less favourable. There is no universally correct diameter.
What a rack and pinion sizing calculator should check
A useful rack and pinion sizing calculator does more than turn Newtons into Newton-metres. It should keep the force path, tooth geometry and assembly interfaces visible together. At a minimum, its output should let you assess these connected conditions:
- linear force, peak force, pinion torque and travel speed;
- module, pressure angle, tooth count and pitch diameter;
- pinion tooth-root capacity and rack tooth loading for the selected material and face width;
- radial loads at the shaft and their effect on bearing selection and bearing spacing;
- stroke length, rack segment length, end clearance and usable engagement.
These are not independent fields. Increasing module can improve tooth strength but makes the mechanism larger and may require a larger pinion, shaft and housing. Increasing face width can reduce tooth stress, yet introduces alignment sensitivity. A wide rack on a flexible mounting surface will not share load across its face as the ideal calculation suggests.
Pressure angle also deserves deliberate selection. A standard 20-degree system is widely used and practical for many compact transmissions. Higher pressure angles can support stronger teeth, but they increase radial force. That force is transferred through the pinion shaft, bearings, housing and mounting structure. Sizing tooth strength without checking the bearing reaction is incomplete engineering.
Pinion tooth count and interference
Small pinions are attractive because they reduce package size and increase mechanical advantage. They can also introduce undercut or interference risks, depending on module, pressure angle, profile shift and tooth system. A valid mechanism needs true involute tooth geometry, not simply a circular pinion with evenly spaced visual teeth.
Where a small pinion is necessary, profile modification may be appropriate. It is not a free correction. Profile shift changes tooth proportions, centre-distance relationships and contact behaviour. The rack and pinion must remain a matched tooth system, particularly if replacement parts or multiple rack sections are expected later.
Size the shaft and bearings with the mesh load
The tangential tooth force that moves the rack also creates a radial component at the pinion. For a spur gear, a first estimate of radial force is based on the pressure angle. At 20 degrees, the radial component is roughly 36% of tangential force. Helical systems introduce axial force as well.
The bearing load seen in practice depends on where the pinion sits relative to the bearings. An overhung pinion increases bending moment. A long shaft, flexible housing wall or loose bearing fit can turn an acceptable tooth calculation into poor mesh contact, vibration and rapid wear.
This is why shaft diameter, bearing bore, bearing spacing and housing geometry should be configured as assembly geometry rather than added as an afterthought. Check static capacity for peak loads, but also consider bearing life at the expected duty cycle. High-speed, frequent-reversal motion may be governed by lubrication, preload and thermal behaviour rather than simple static load rating.
Backlash belongs in this stage too. Some positioning systems require controlled backlash or preload. Others tolerate clearance and benefit from lower friction. A spring-loaded split pinion or compliant rack mounting can reduce lost motion, but it increases complexity and may raise bearing loads. The correct choice depends on repeatability requirements, external load reversals and whether the axis is measured directly at the carriage.
Validate the rack as an installed component
A rack has to be straight, supported and aligned over its working length. The stroke is rarely the same as the rack length. Allow for pinion run-on, end clearances, mounting features and the minimum tooth engagement needed at each travel extreme. When racks are joined end to end, joint quality matters. A pitch error at one joint can create a noticeable torque spike and positional disturbance.
Mounting stiffness is equally important. A rack fixed to thin sheet can follow every local distortion in the structure. A machined reference face or a properly designed support beam provides a more reliable basis for mesh alignment. Consider thermal expansion on long axes, especially where the rack material and supporting frame differ.
Inspection should make these constraints visible. Look at the mechanism in three dimensions, isolate the pinion and rack contact region, and examine shaft clearances, bearing seats and housing walls. An exploded view is useful for confirming that the design can be assembled in the intended order, with access for fasteners and adjustment.
Move from calculation to production geometry
A result is only useful when it becomes buildable parts. The practical workflow is configure, inspect, validate and export. Configure the force case, travel and ratio first. Inspect the pinion, rack, shaft and bearing layout as an assembly. Validate tooth geometry, loads and clearances. Then export geometry that preserves the design intent for machining, additive manufacture or further CAD integration.
GearSuite follows this mechanism-first approach by combining true involute rack-and-pinion geometry with shafts, bearings, housings and exportable solids in one browser-based workspace. The benefit is not merely faster calculation. Decisions stay visible while the mechanism is still easy to change.
Choose the smallest rack-and-pinion system that meets the real force, life and stiffness requirements with reasonable margin. Then inspect the load path one more time. The most useful calculator result is the one that leads directly to parts your workshop can make and your machine can rely on.